Robots Hop, Flip, Swim with New Elastic Rod Movement

Roboticists at the UCLA Samueli School of Engineering and the University of Michigan have developed a new method for robot movement. They demonstrated that elastic rods, when bent and twisted, can repeatedly snap between shapes. This action releases stored energy, allowing small robots to hop, flip, and swim. The technique offers a new approach for machines limited by size, weight, and power output, aiding traversal of uneven land and water.
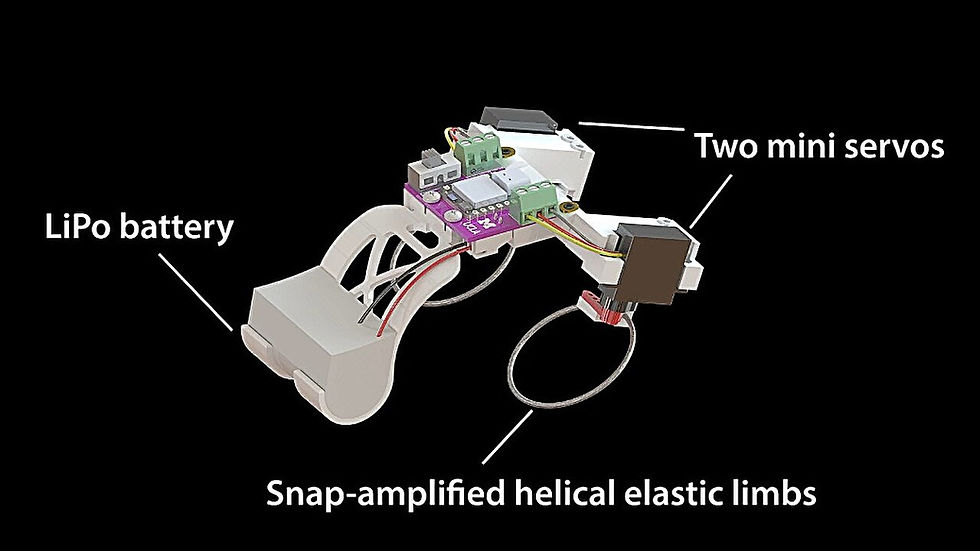
According to TechXplore, the study, detailed in *Science Advances*, explores how energy accumulates within an elastic rod when bent and its ends rotated. This reaches a critical point where the rod shifts configuration, discharging held energy. Specific shapes deform gradually, but others snap quickly, releasing energy in a sudden burst. Geometry selection is central to achieving strong, repeatable snapping motion.
And these elastic rods differ from conventional beams, columns, or trusses, combining bending, twisting, and compression. This enables substantial three dimensional deformations and targeted releases of elastic energy. A motor moving and rotating the ends of a straight rod can create the helical shape required, providing a simple power mechanism for small robots. Khalid Jawed, an associate professor of mechanical and aerospace engineering at UCLA Samueli, noted that a rod's shape, not its size, dictates its snapping behaviour. This applies across scales, allowing small motor movements to convert into powerful bursts for robots merely a few millimetres wide.
The research team first created computational models of elastic rods to predict their responses under varying bending and twisting combinations. They then verified these predictions by using a robotic arm to repeatedly deform physical rods. These simulations and experiments led to established design rules. These rules guided the development and construction of a robot prototype resembling a frog. This prototype utilised helically shaped elastic rods as its snapping actuators.
But the motor only winds up the rod slowly. The rod itself stores and releases the energy, meaning a small, low power motor can initiate the snap. This sudden discharge of stored energy propels the robot forward. Dezhong Tong, a co first author who contributed to the project during his doctoral studies at UCLA and is now a postdoctoral researcher at Michigan, stated that predicting a rod's snap point allowed them to convert simple motor action into a forceful push. This push sends the robot hopping.
The robot prototype, 11 centimetres long and weighing 98.2 grams, moved across various surfaces: wood, cloth, acrylic, leather, grass, and sand. It also climbed steps. This snapping mechanism prototype moved faster across all six tested surfaces compared to a robot with rigid legs. On wood, it peaked at 3.21 body lengths per second. Its average speed across all terrains was 2.46 body lengths per second, exceeding the 0.79 body lengths per second of its rigid legged counterpart. The difference was most noticeable on cloth and grass, where the rigid legged robot nearly stopped.
So, the snapping mechanism additionally enabled the robot to launch into the air and complete repeated backflips. Fitted with thin, flexible fins, the same robot swam at approximately 0.5 body lengths per second. It could also turn and navigate around obstacles, maintaining course even when subjected to wind disturbances. The team showcased the snapping actuator's versatility in intricate environments. Researchers remotely operated the robot through a sandbox with rock impediments, integrating its movement with light sensors for autonomous steering.
Xiaonan Huang, an assistant professor of robotics at Michigan and co leader of the research, indicated that the aim is to allow the robot's mechanics to perform tasks typically requiring larger motors or more complex control systems. He explained that by programming when an elastic structure stores and rapidly releases energy, small robots can gain access to powerful, repeatable motions without demanding continuous high output from the motor. Other authors on the paper include Jiaqi Wang, Zexiong Chen, Andy Borum, and Weicheng Huang.
Elastic rods, when bent and twisted, snap to release stored energy, enabling robot locomotion.
The technique allows small robots to hop, flip, and swim across varied terrains and water.
A prototype robot, 11 centimetres long, moved faster than rigid legged counterparts across six surfaces.
Small, low power motors can trigger powerful movements as the rod itself stores and releases energy.
The research offers a method for creating robots operating in complex environments without continuously demanding high motor output.
Source: TechXplore